demo source-backed
Jev × LIBERO: robot decisions with local physics previews
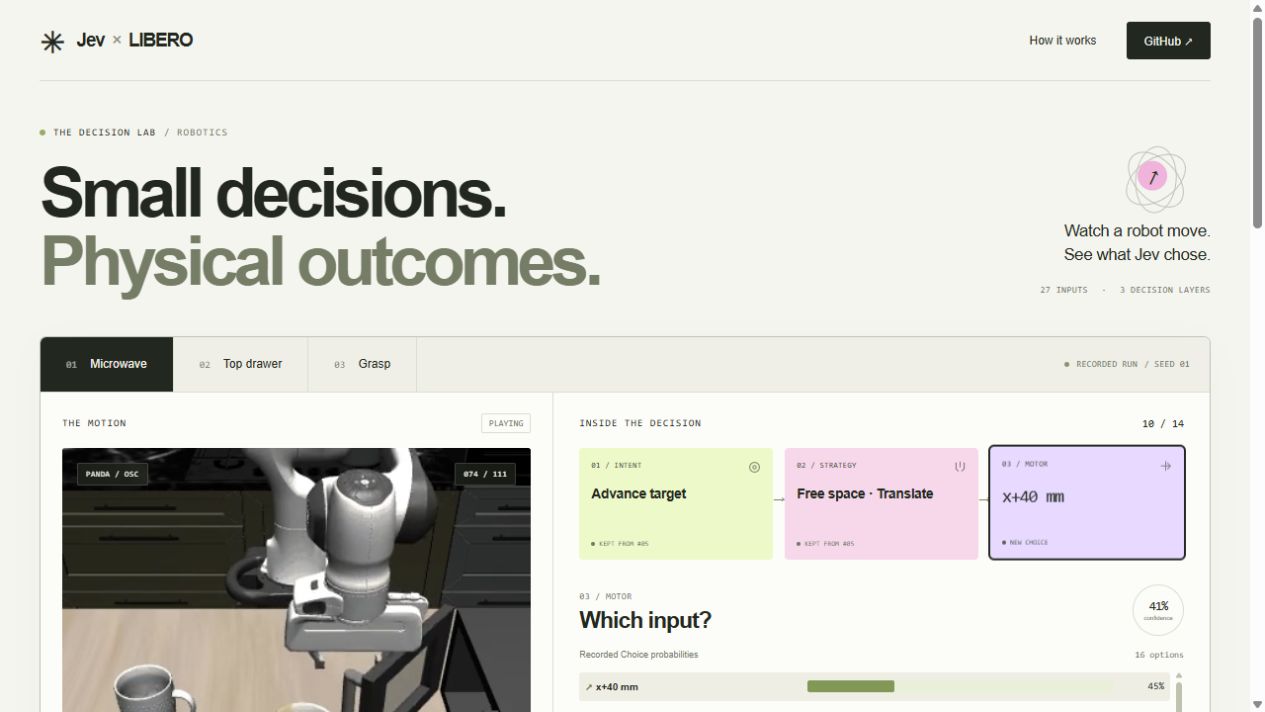
A configurable LIBERO robot-control experiment that combines Jev decisions with reversible physics previews. An interactive replay follows intent, motion family and control choices alongside saved trajectories.
Notes
The repository includes three seed-1 task records passing their LIBERO criteria: microwave closure in 14 decisions, drawer closure in 20, and soup-can placement in 40; the controller offers 27 control inputs.
source-backed — Public repository, docs or live artifact. About this label